Robot #5
Not started yetNo reported fault recorded.
- 1 Power gate 1
- 2 USB link gate 2
- 3 Bus roll-call gate 3
- 4 Joint health gate 4
- 5 Calibration gate 5
- 6 Repair gate 6
Expansion board — micro:bit V2
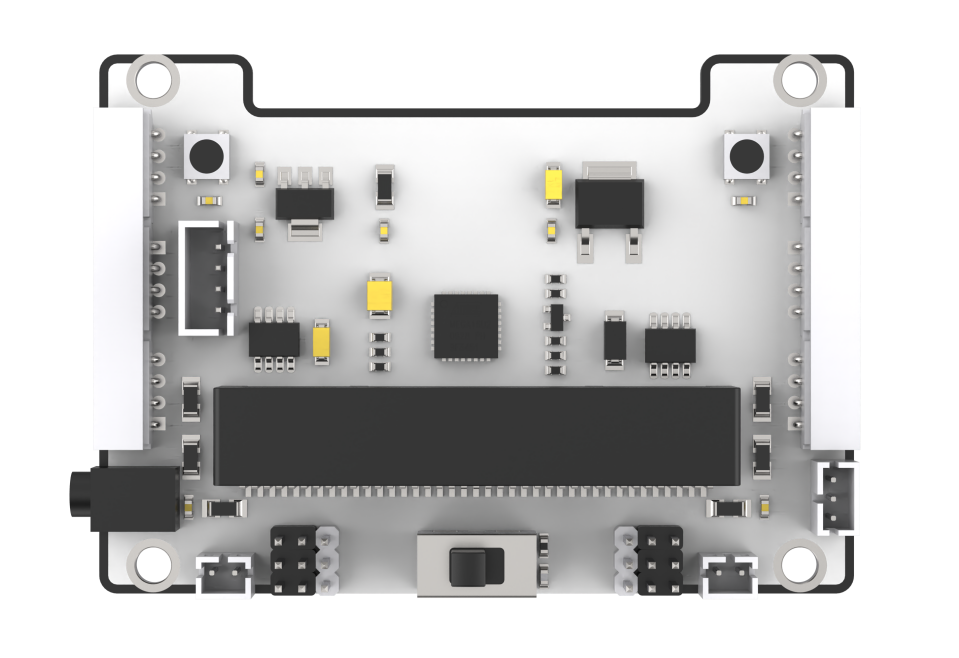
8 of 11 — the interface names are Hiwonder's, but these positions are read off their render rather than a real board, and show dashed. Check them against the unit before relying on this.
Servo map — palm view
Joints are numbered from the fingertip. 1 tip joint, 2 middle joint, 3 base joint on the palm edge, 4 knuckle inside the palm. The parts between them are lettered the same way: A tip segment, B middle segment, C base segment. So the middle joint of the ring finger is ring 2, and the part above it is ring B.
Servos 1 to 5 are the fingers, thumb through little. Servo 6 turns the base. Six leads were found in the wrong ports on this unit, so record what actually moves rather than what the port is labelled.
Rig map — fingers, wrist, base and controller
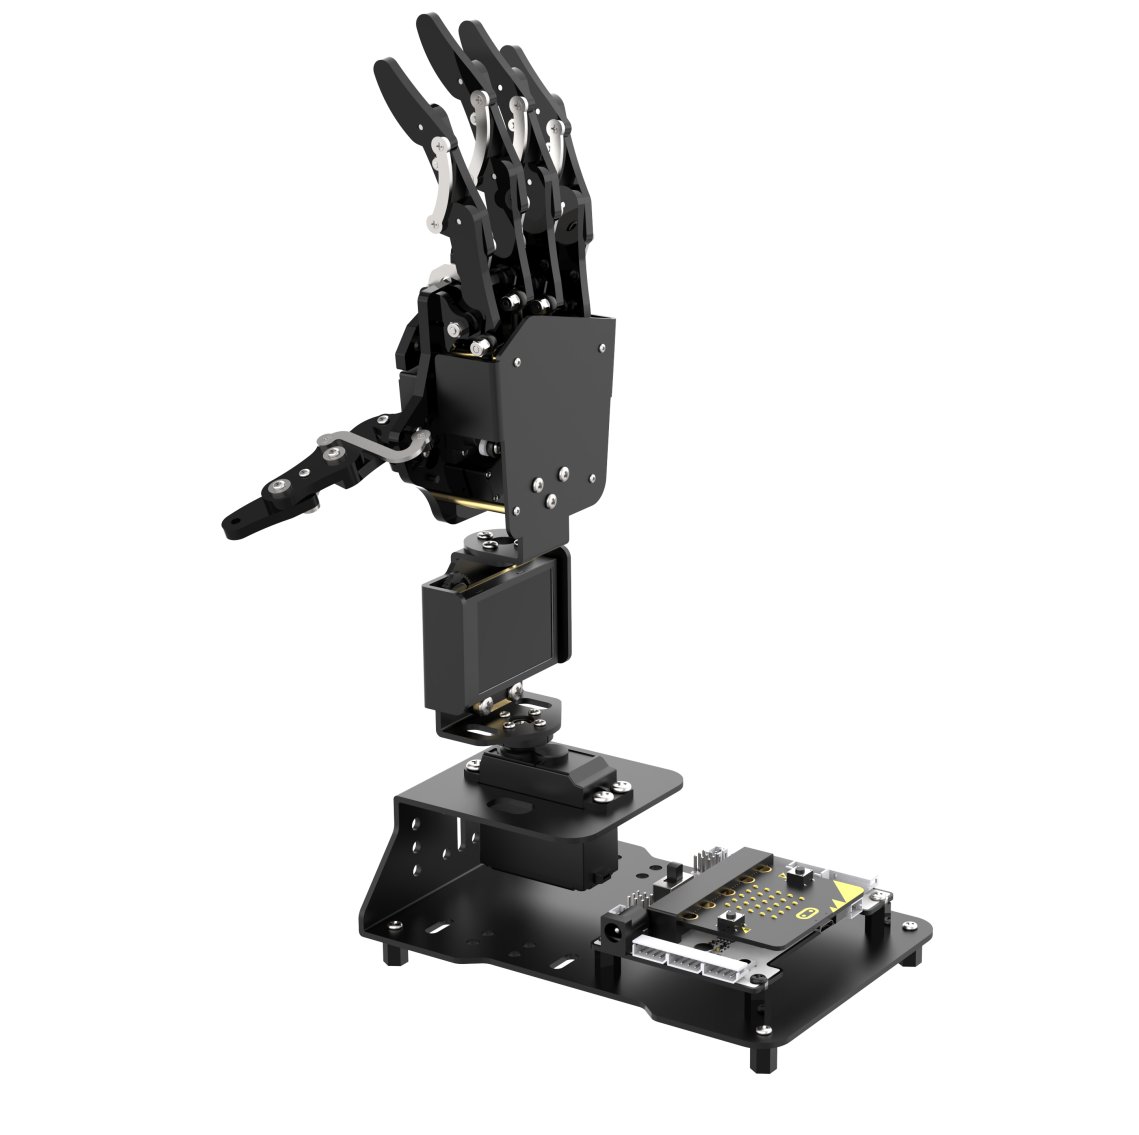
3 of 12 — positions are inferred from Hiwonder's render and show dashed. The docs say six joints — five fingers plus one pan-tilt — but the render shows a servo below the palm and another at the base. Confirm on the unit whether that is one joint or two.
Click a part to record its state. Which servo port drives which finger is not yet verified — move one port at a time and watch what curls.
Observations
Nothing recorded yet.